Aven
Sole engineer on the loan officer outreach platform used to originate ~2000 customers + on-call for all loan officer tooling.
I'm Ethan, a third-year undergraduate studying Electrical Engineering and Computer Sciences at UC Berkeley. I'm excited about robotics, financial infrastructure, and agentic systems.
At the AUTOLab (part of the Berkeley Artificial Intelligence Research cluster), advised by Prof. Ken Goldberg, I work on robot learning for manipulation, focusing on agentic real-to-sim and sim-to-real reinforcement learning. Previously, I've worked on reward models for robot data curation (CoRL 2026), grasp planning for asymmetrical grippers (CASE 2026), and cable tracing with targeted robot manipulation primitives, which I presented at IROS 2026!
Sole engineer on the loan officer outreach platform used to originate ~2000 customers + on-call for all loan officer tooling.
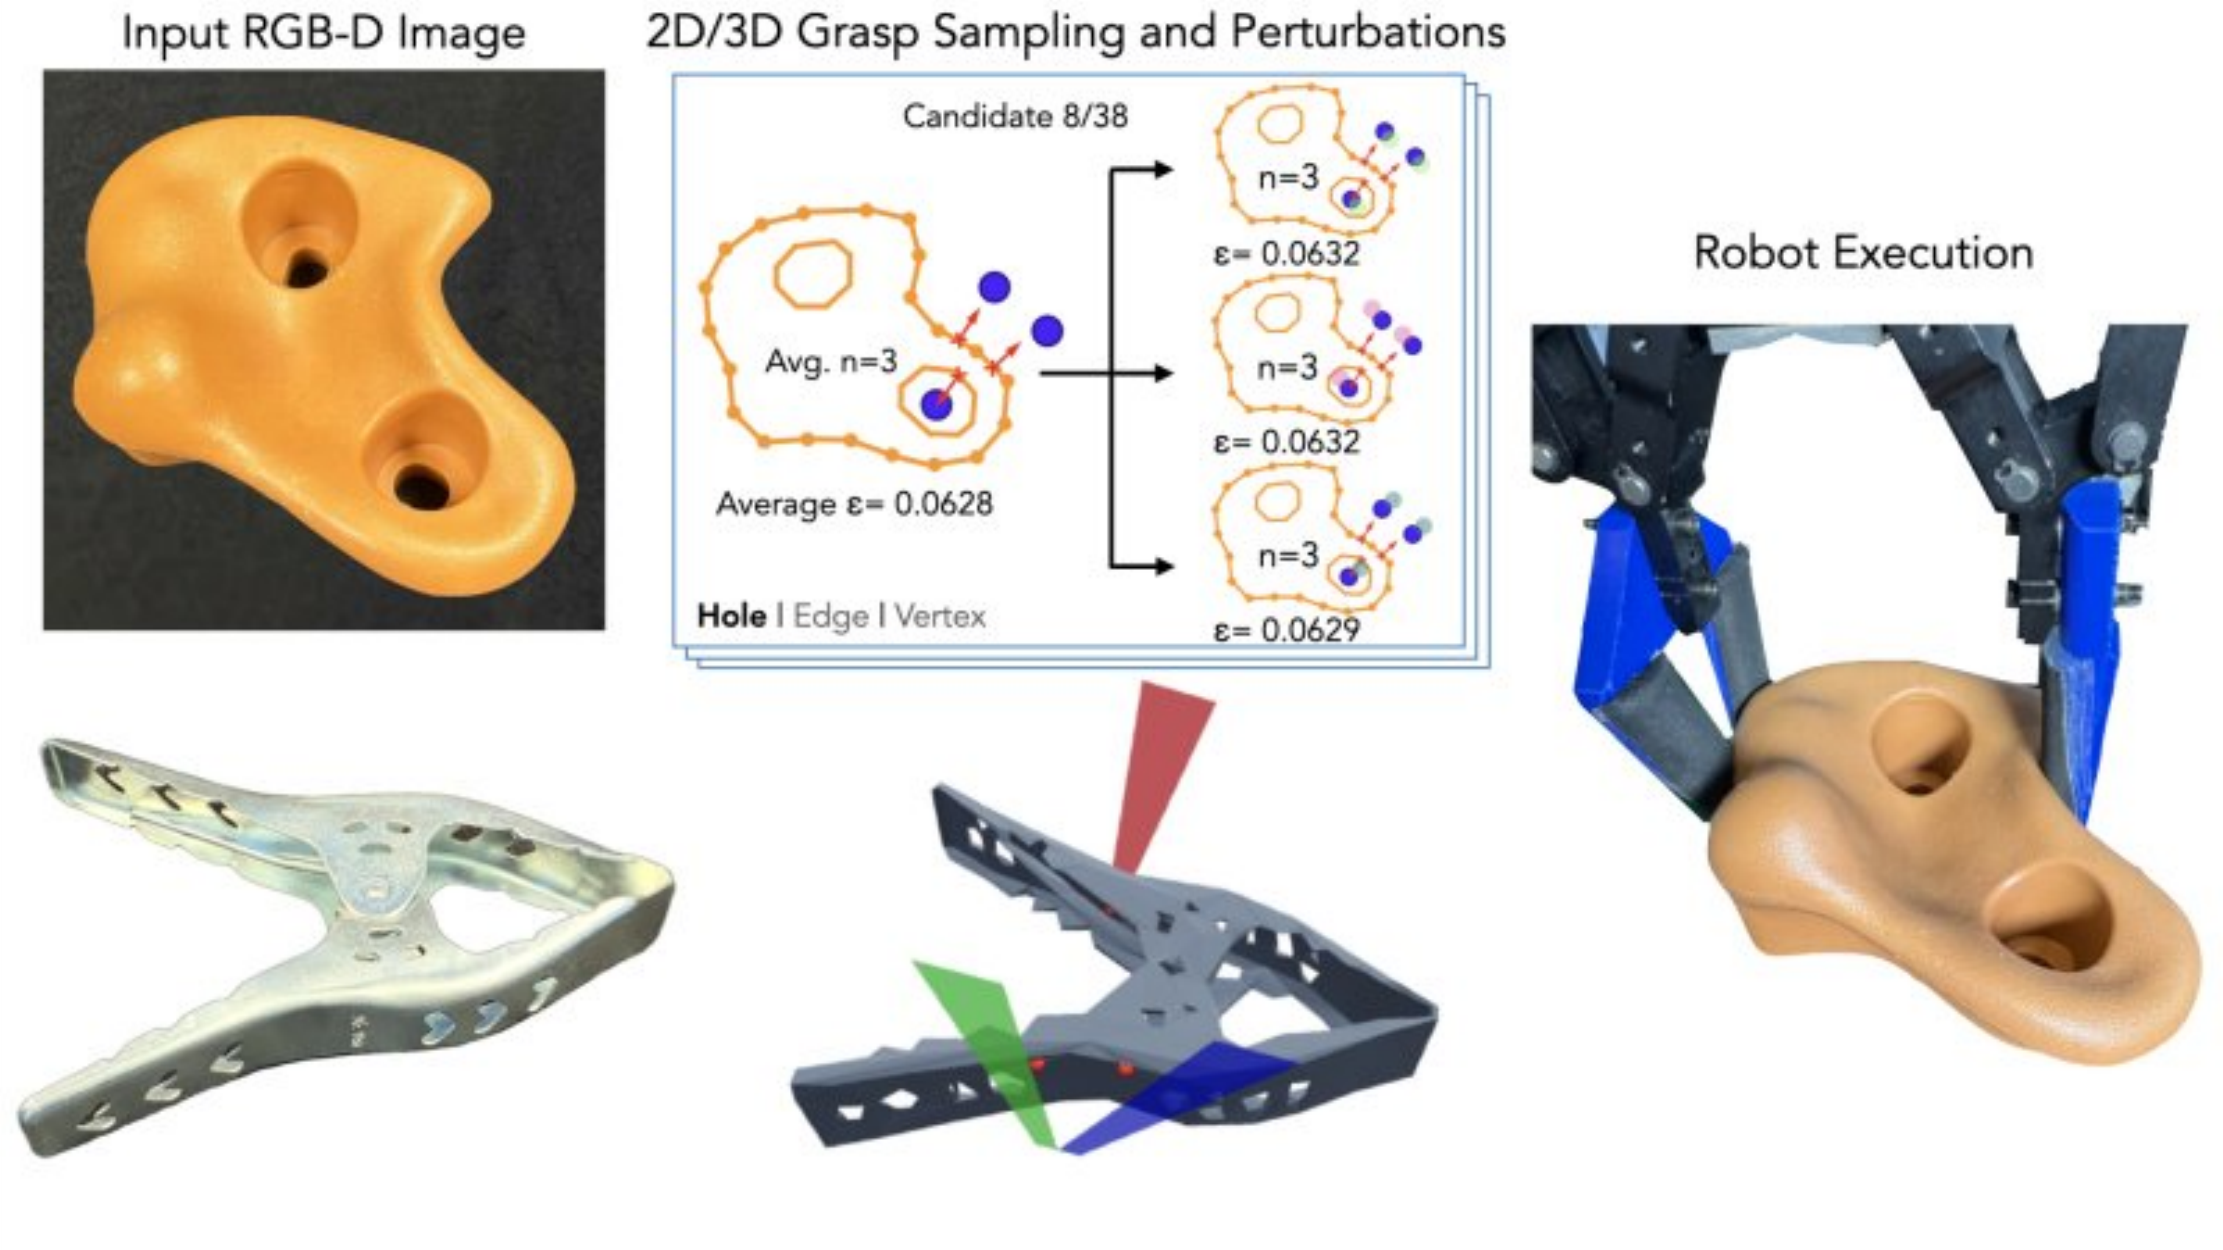
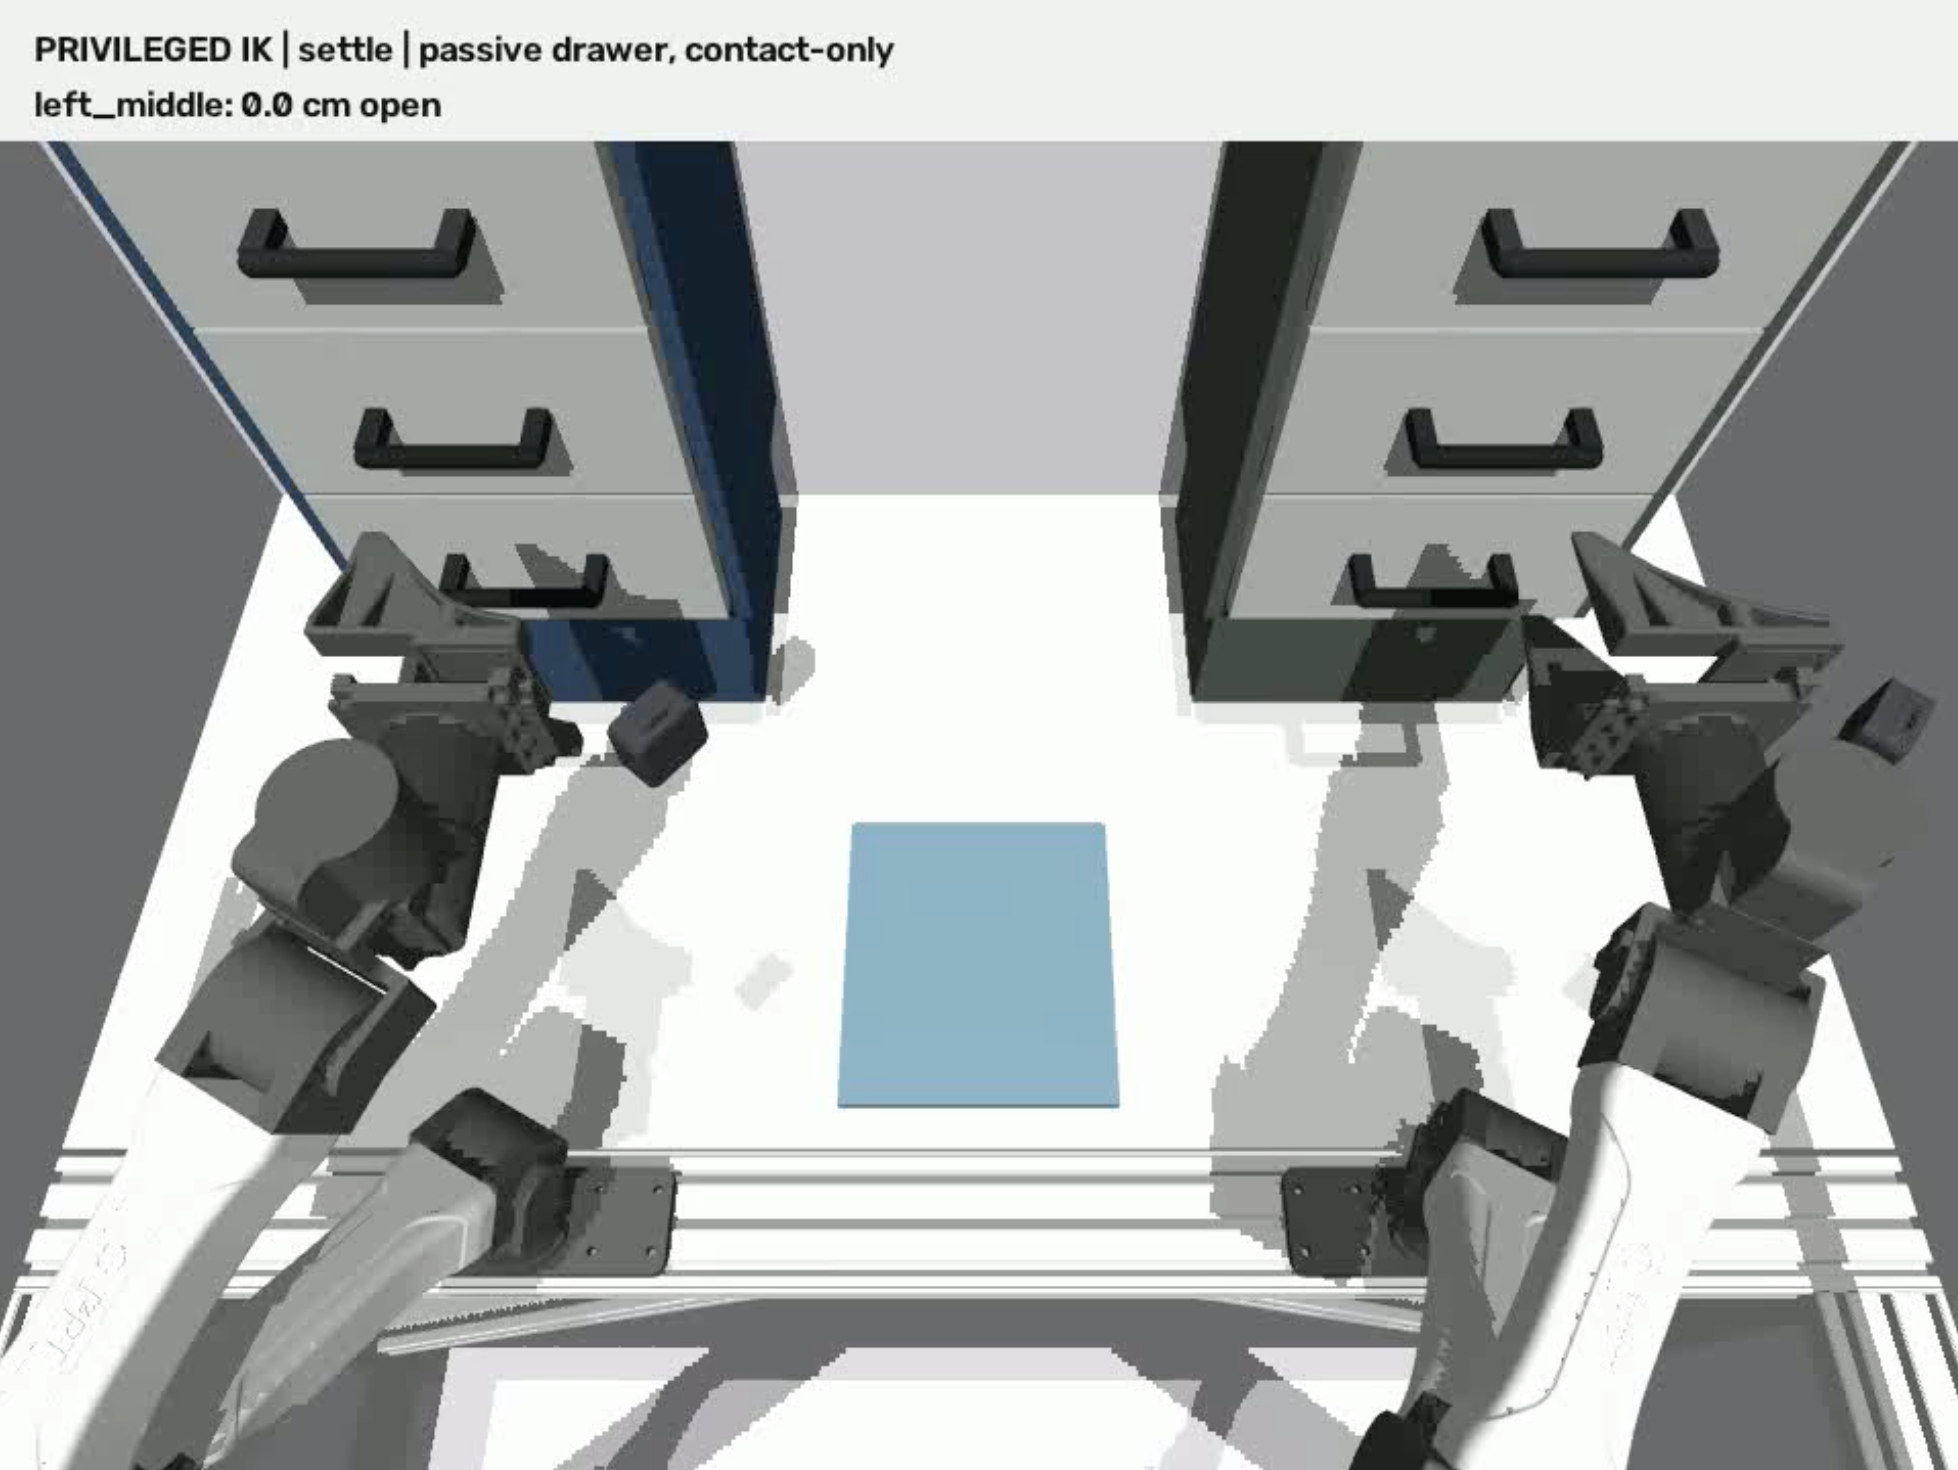
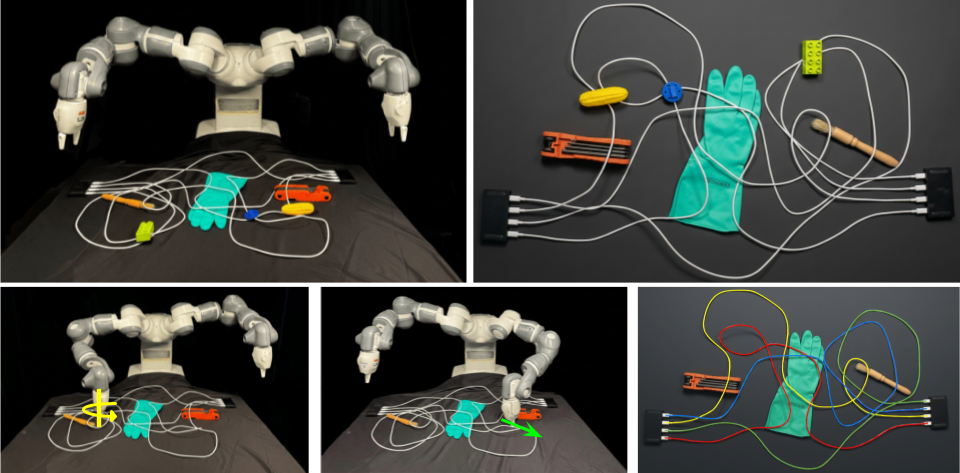

Grasp planning, cable tracing, reward models for data curation, and now real-to-sim-to-real RL for manipulation. Papers accepted to CoRL, IROS, and CASE.
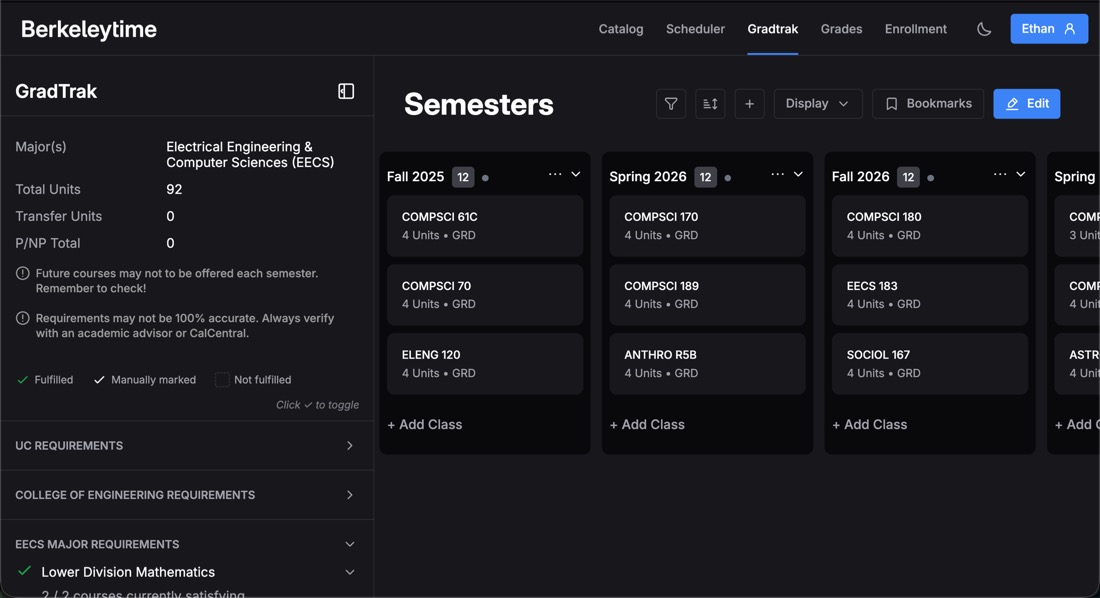
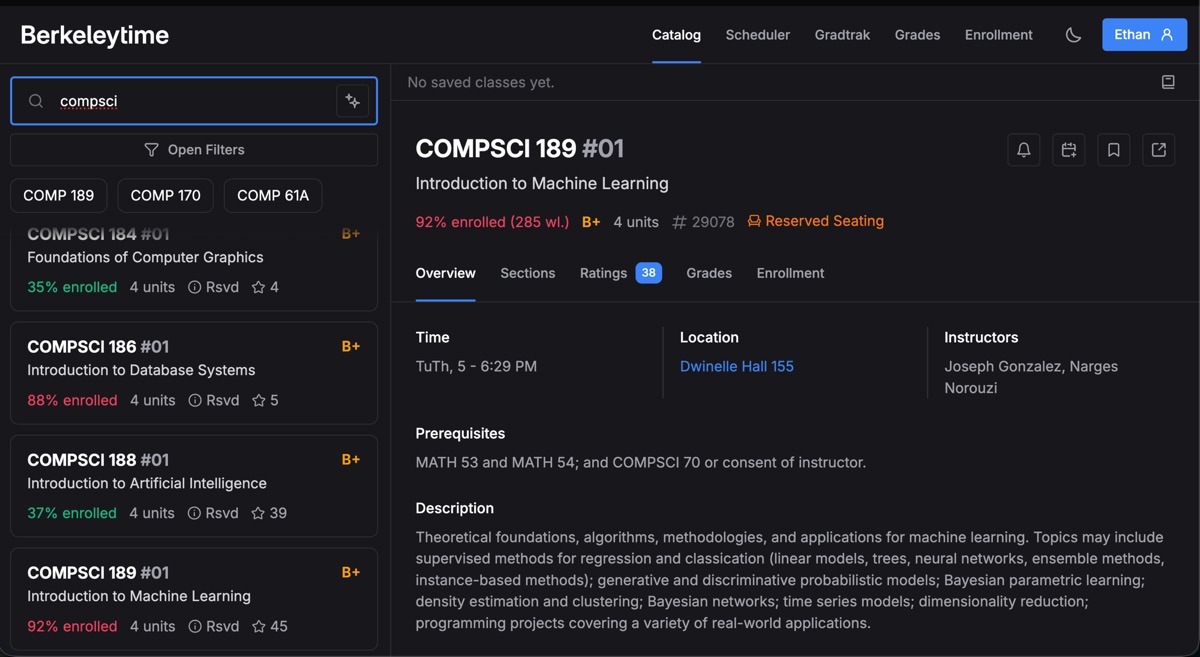
Building optimal course-to-requirement matching for students' four-year plans.
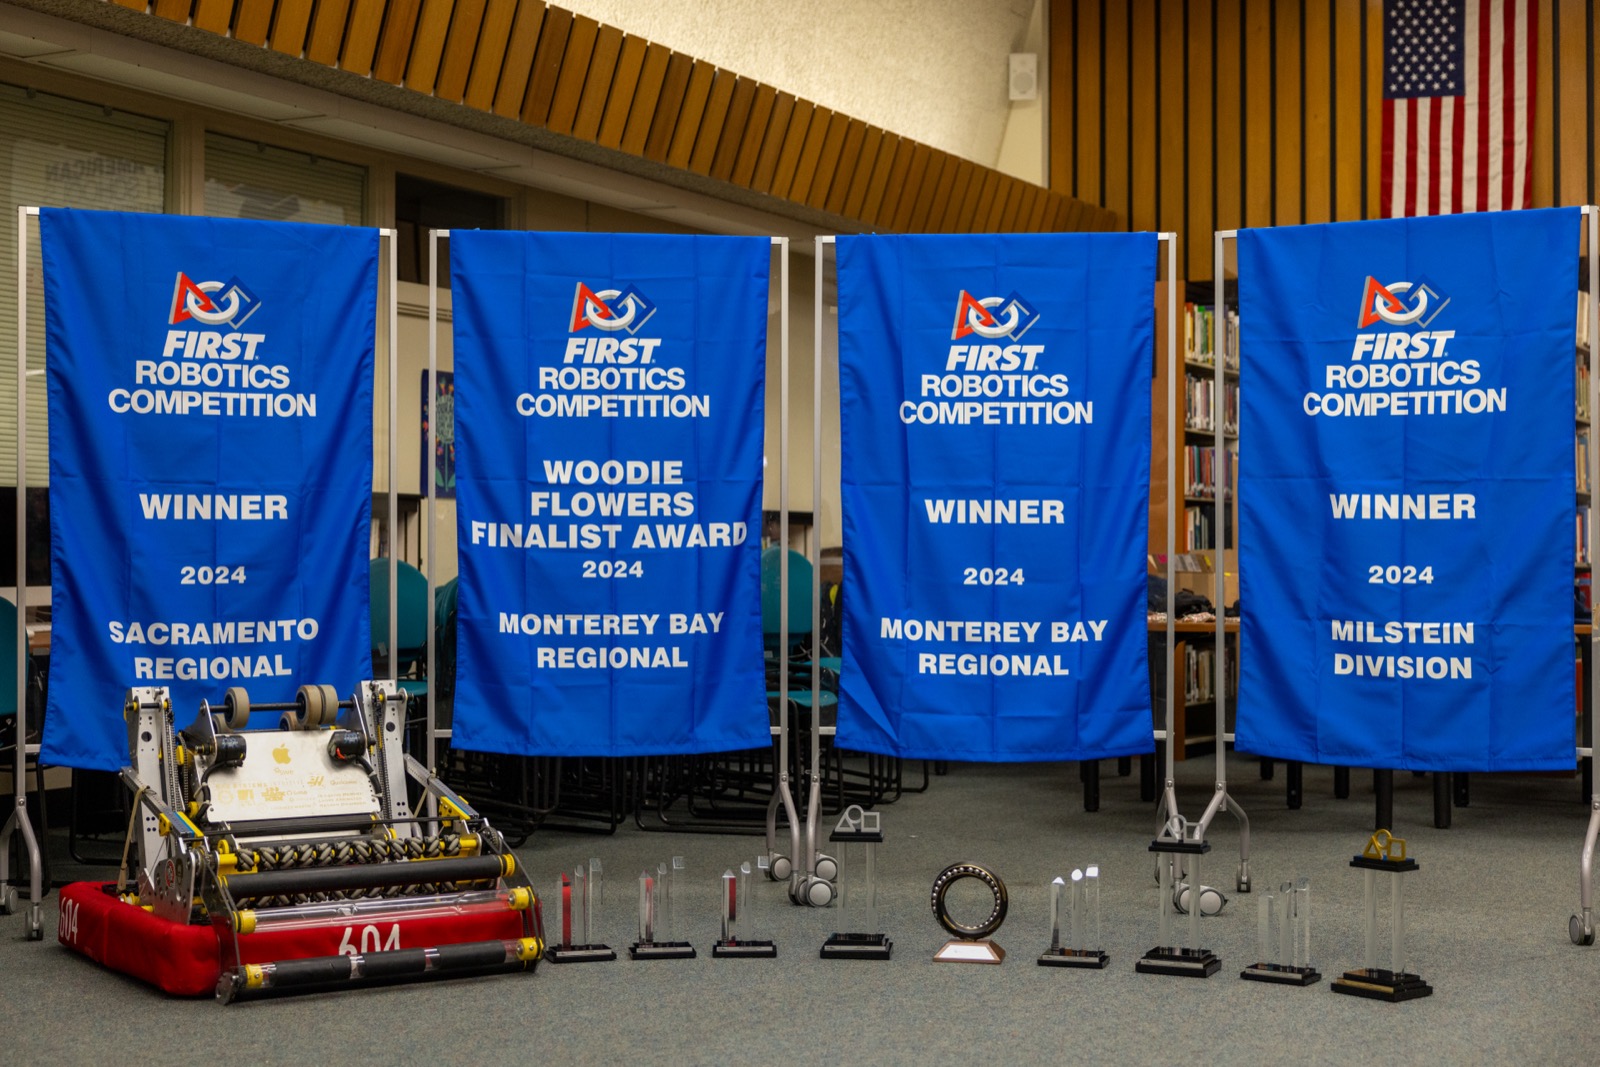
Led the team my last two years, writing the motion planning, localization, and control code and designing the robots. I also taught 30+ new members programming and CAD.
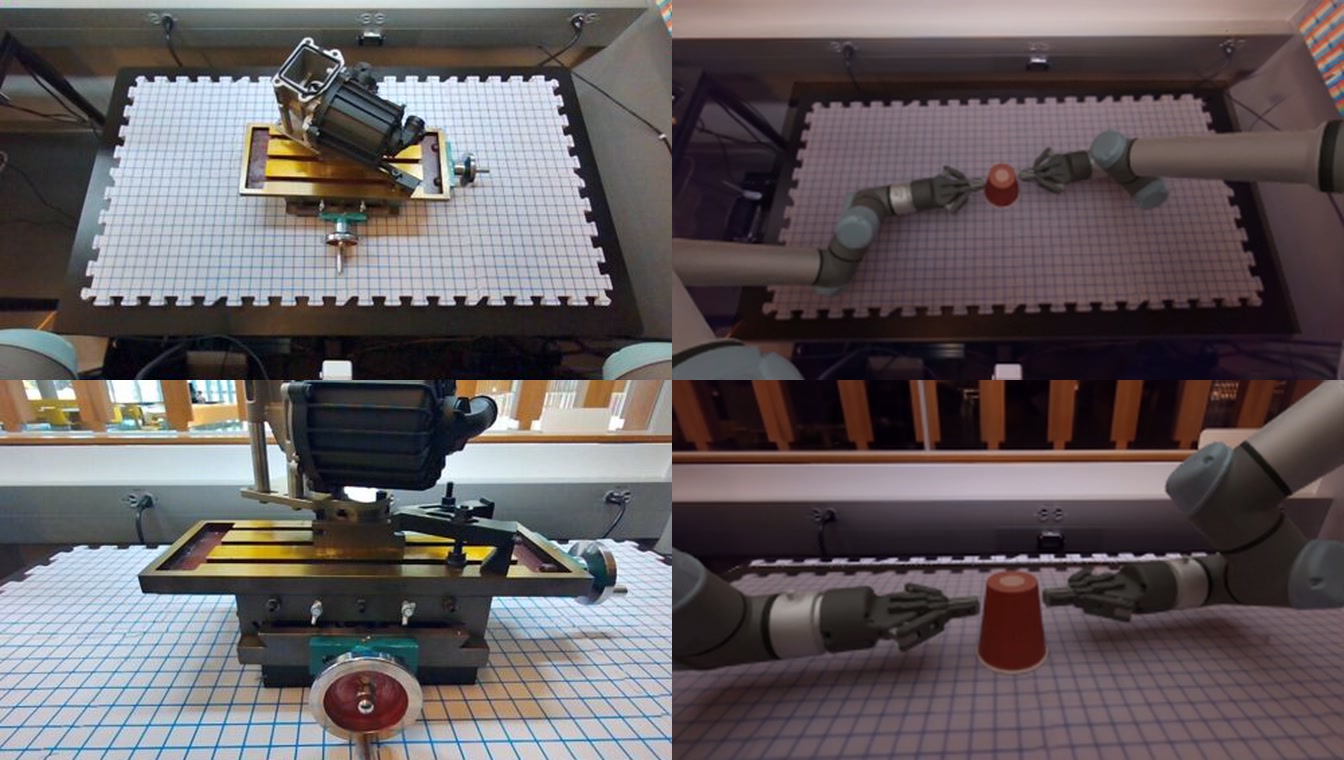
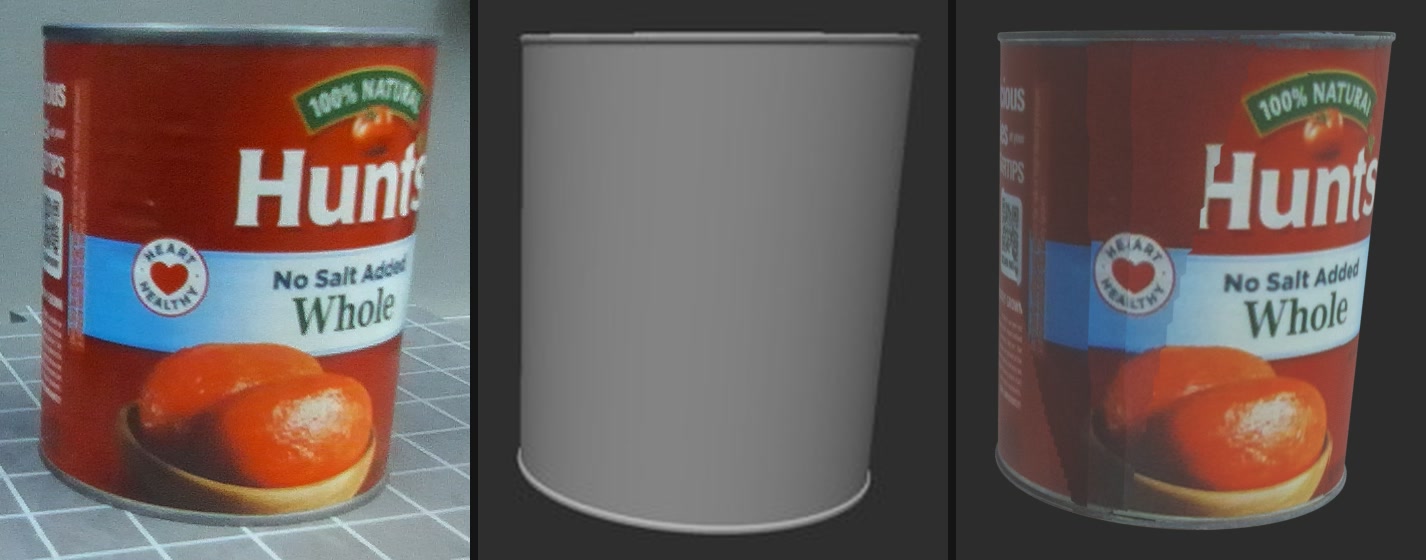
One stereo object capture + one human demo → PPO in a MuJoCo Warp environment → VLA post-training with rendered actor rollouts → non-prehensile manipulation in real. Click here for more details!
I built the software (and hardware) that allows this robot to shoot while driving with one button. It solves the projectile physics every 20ms, leads the shot to cancel its translational motion, and incorporates feedforward and feedback control to achieve ~90% accuracy. This helped us win our championship division and rank #12 globally!